Selected projects
Four things I built.
01
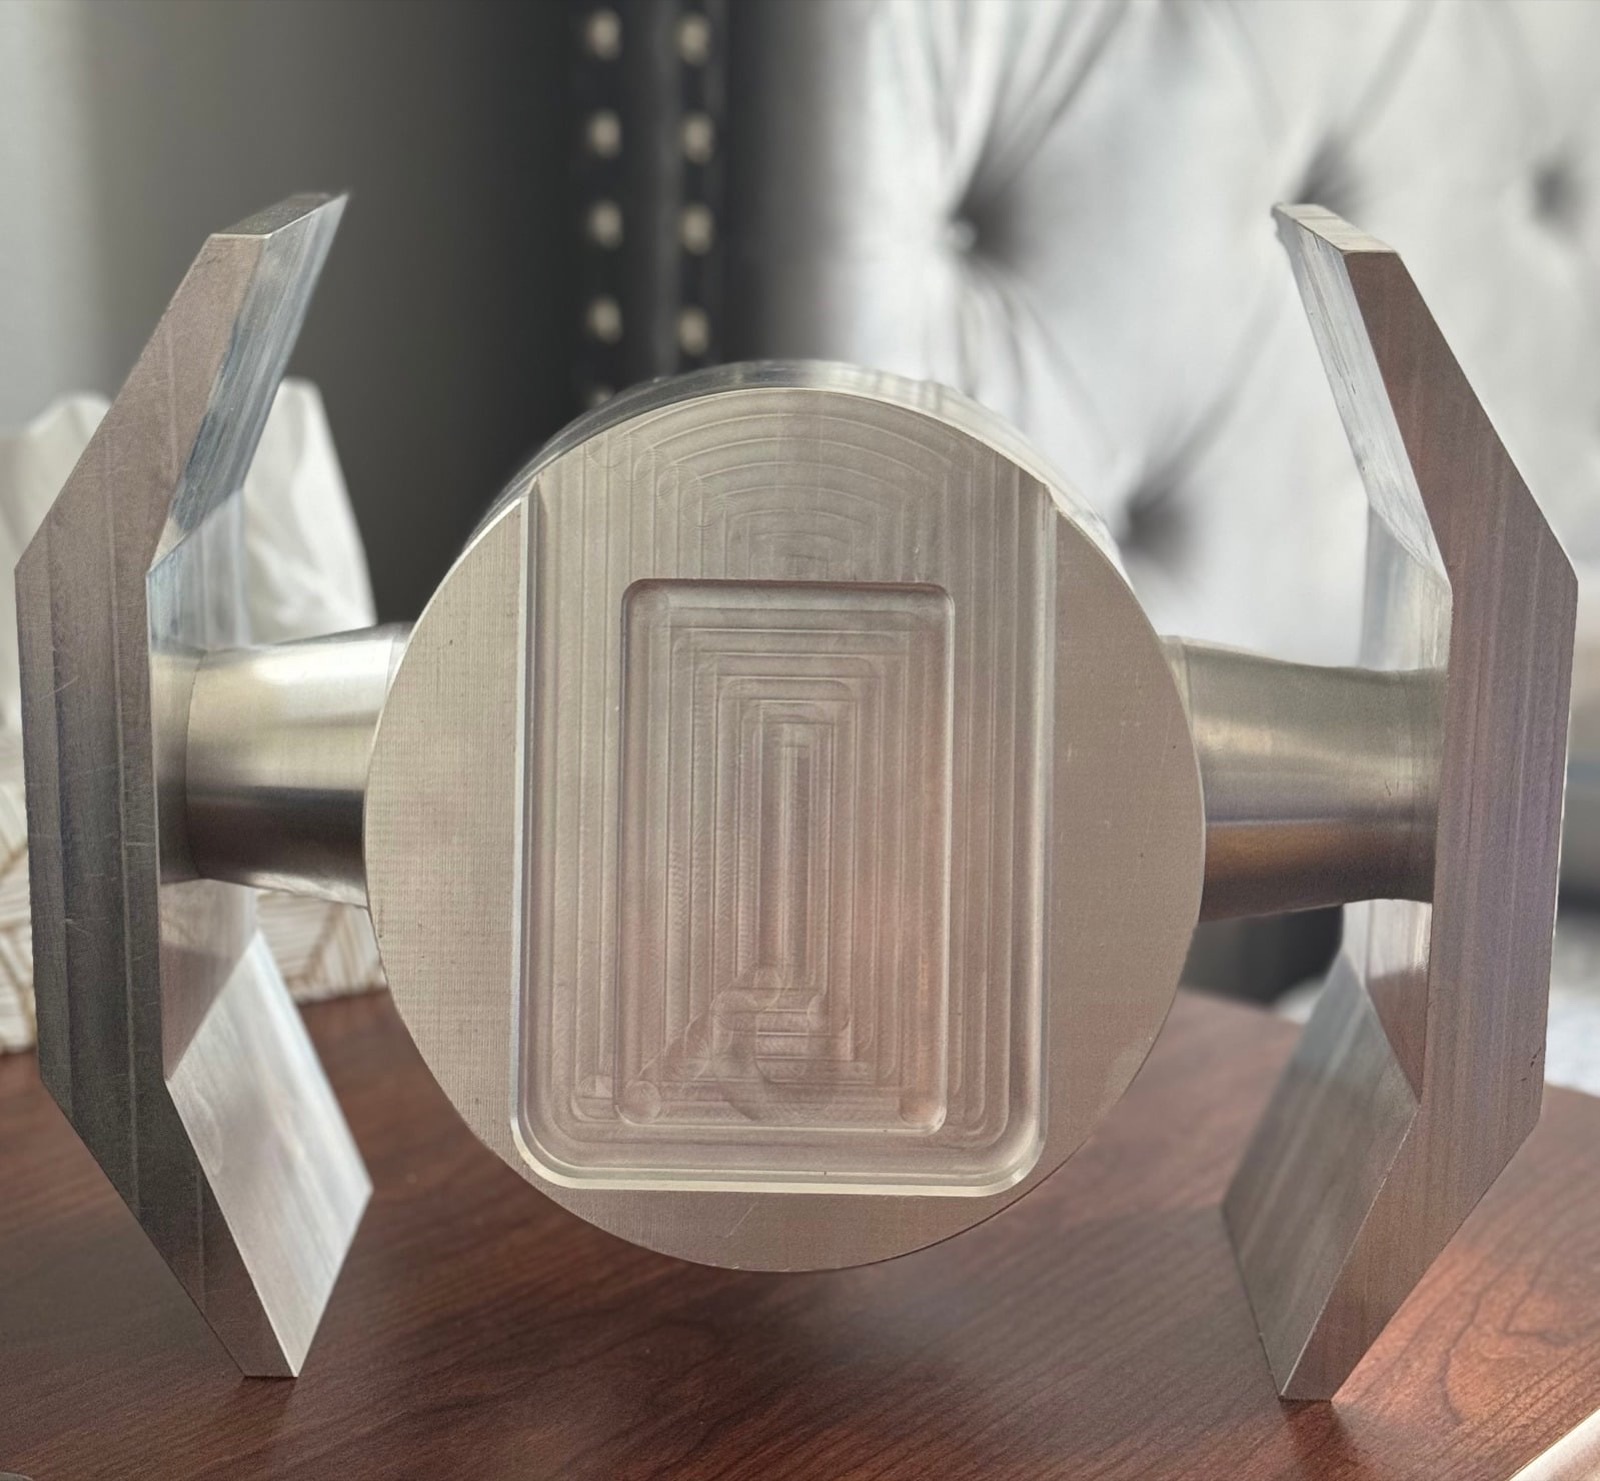
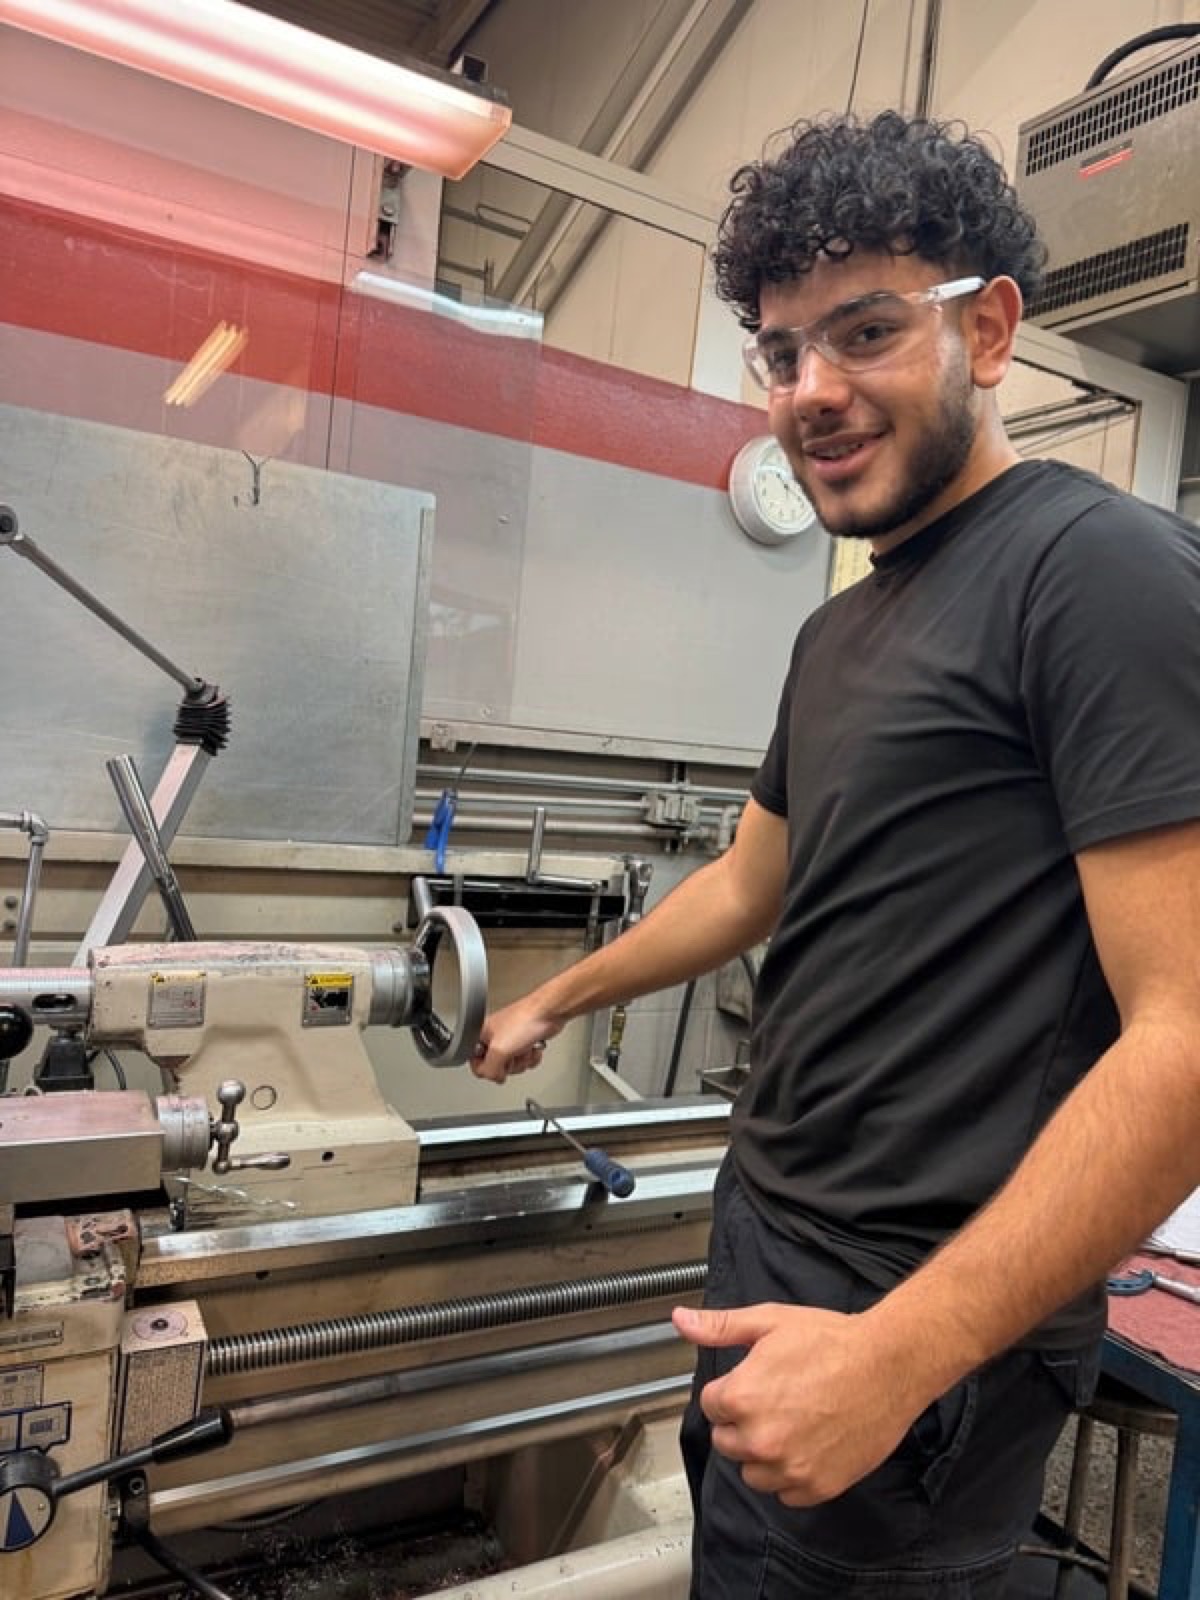
Wireless Charging Stand
What
A custom made, Star Wars themed wireless charging station
machined from high grade aluminum.
How
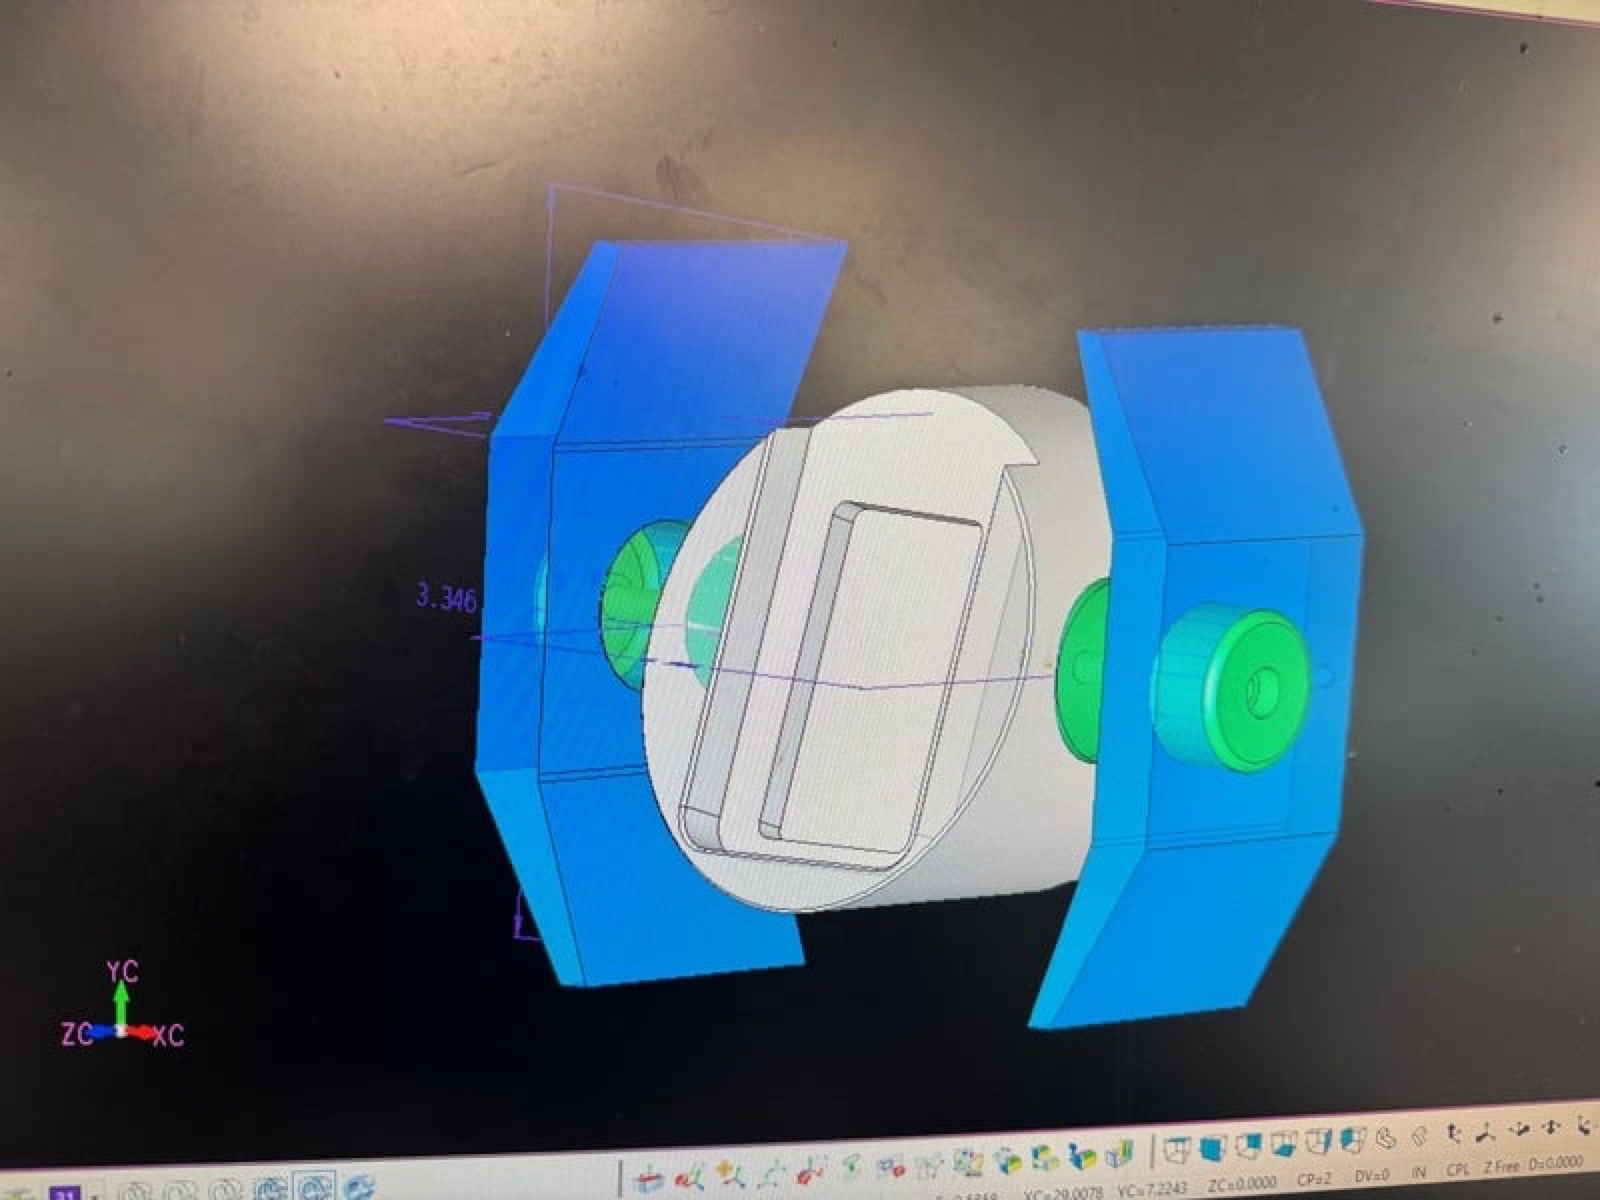
Modeled in AutoCAD and optimized for cost and aesthetics.
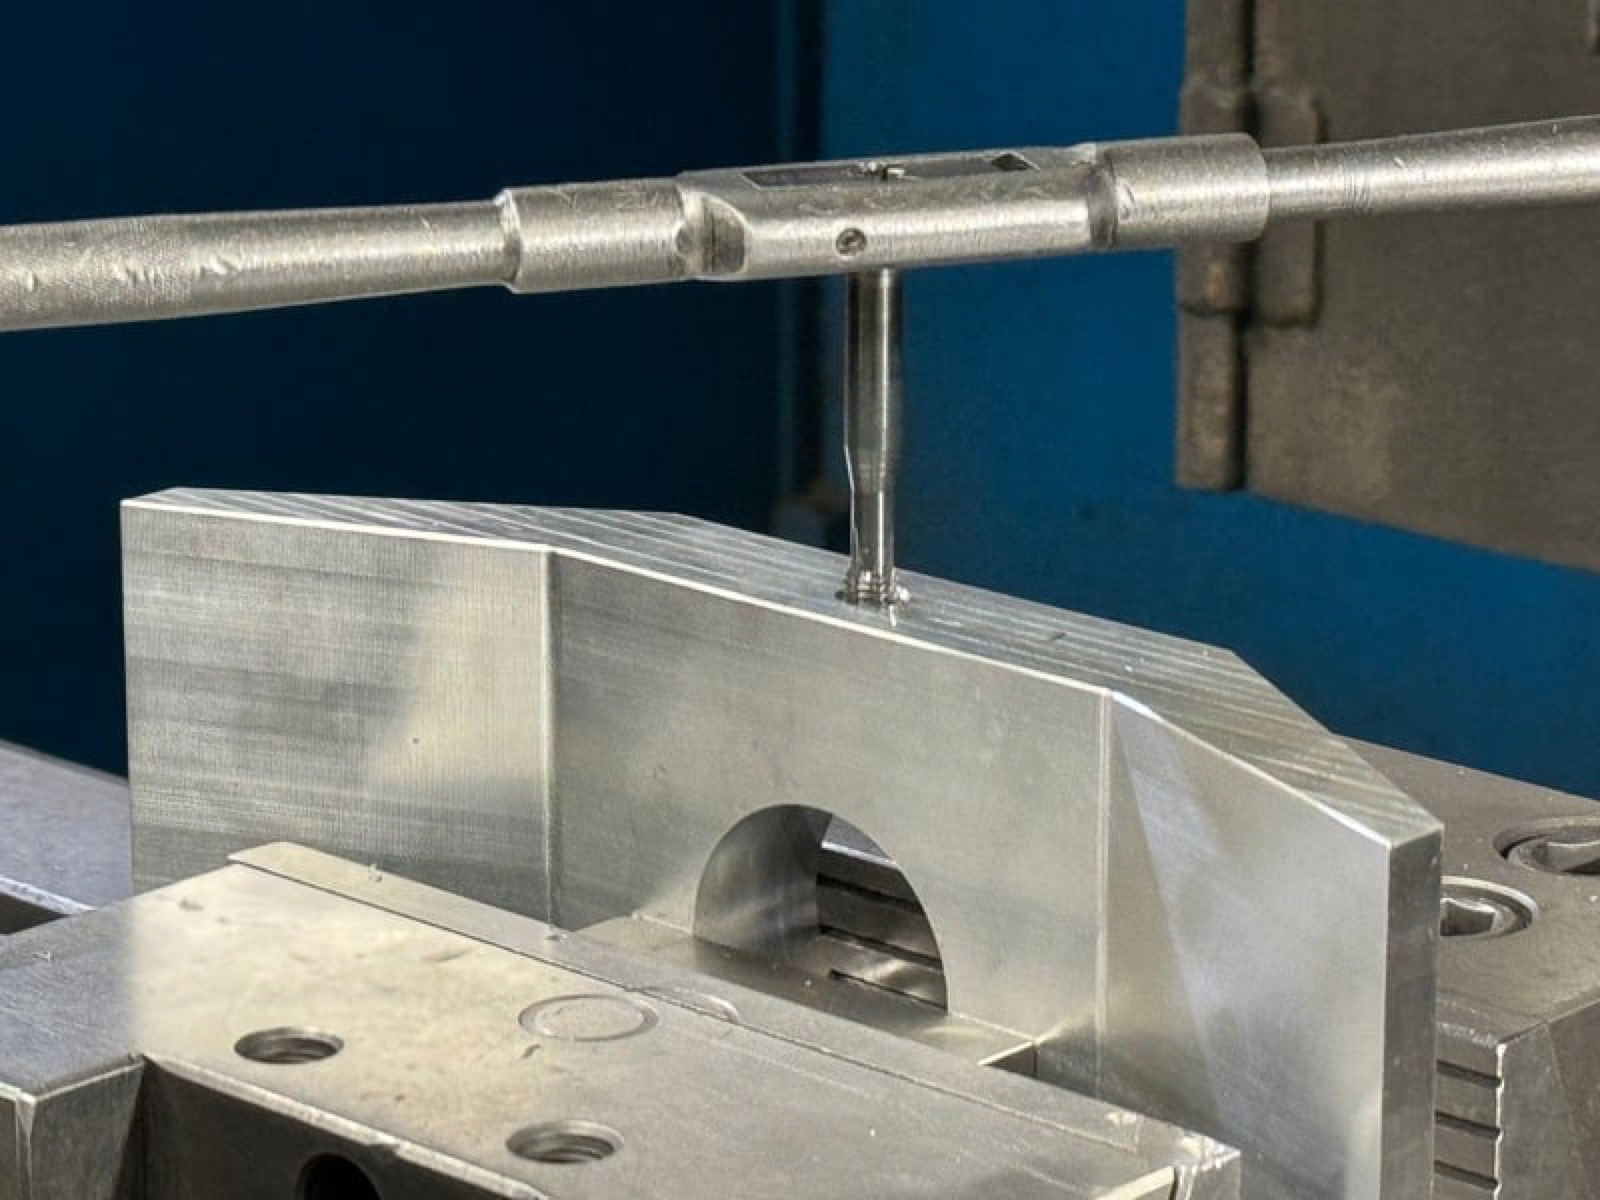
Used industrial CNC machinery at Multimatic to fabricate the
aluminum components, then integrated a wireless charging core
into the assembly.
Results
A fully functional, high fidelity industrial prototype that
brings mechanical design and consumer electronics together in
one part.
02
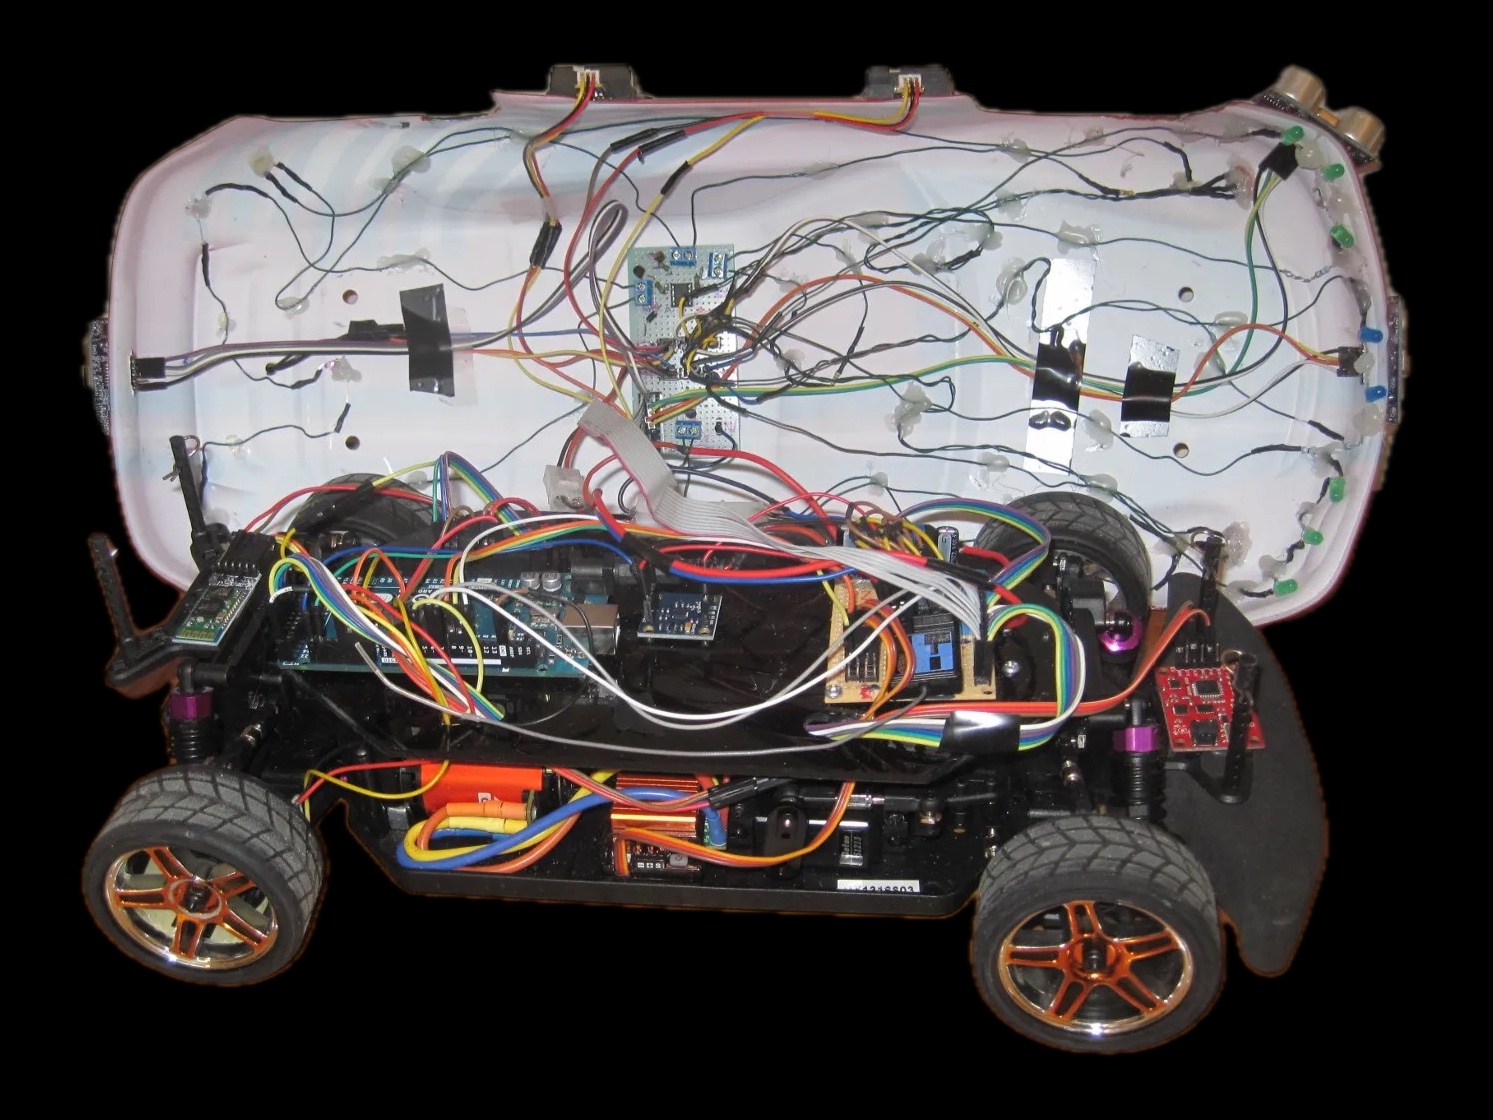
Autonomous Vehicle
What
A fully autonomous robotic vehicle engineered to navigate
terrain and perform real time obstacle avoidance.
How
Developed the navigation logic in C++, integrated ultrasonic
sensors with an Arduino Uno for spatial awareness, and
engineered a custom circuit prototype and protective shell.
Results
A vehicle that crosses unpredictable terrain without
collision, putting embedded systems, mechatronics, and
software development to work in one build.
03
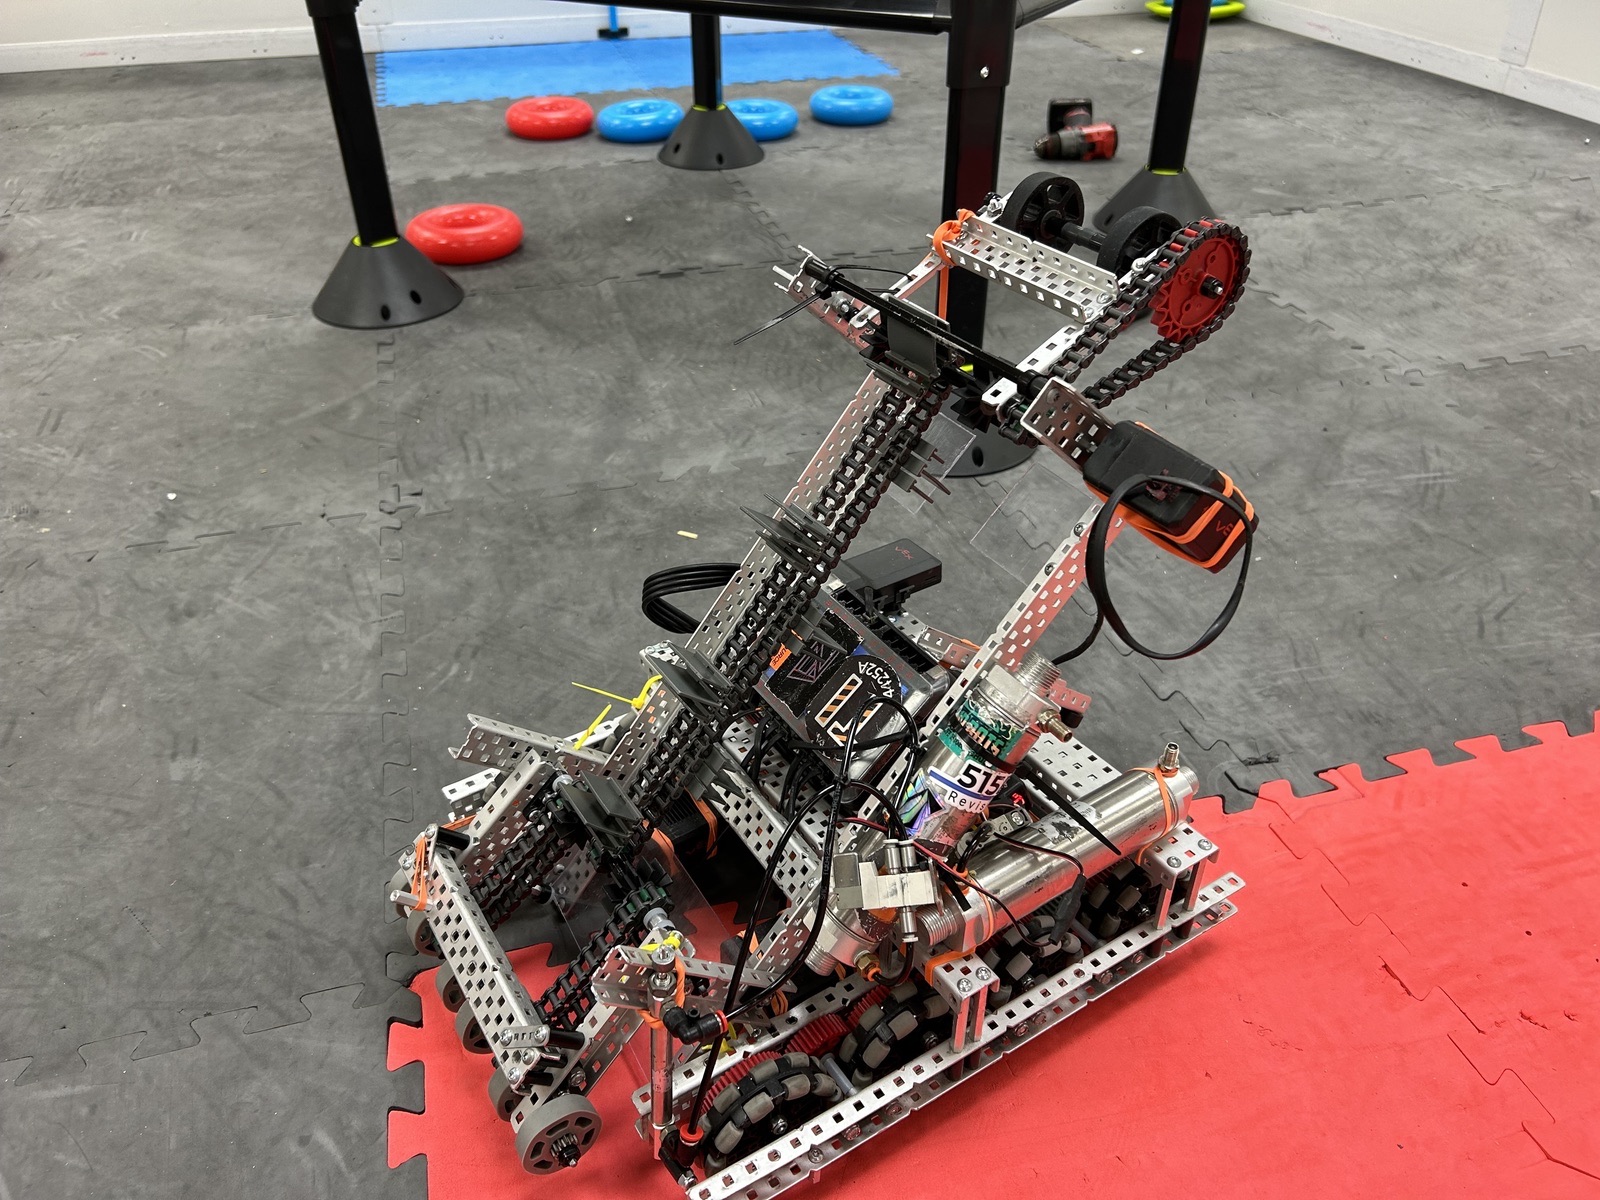
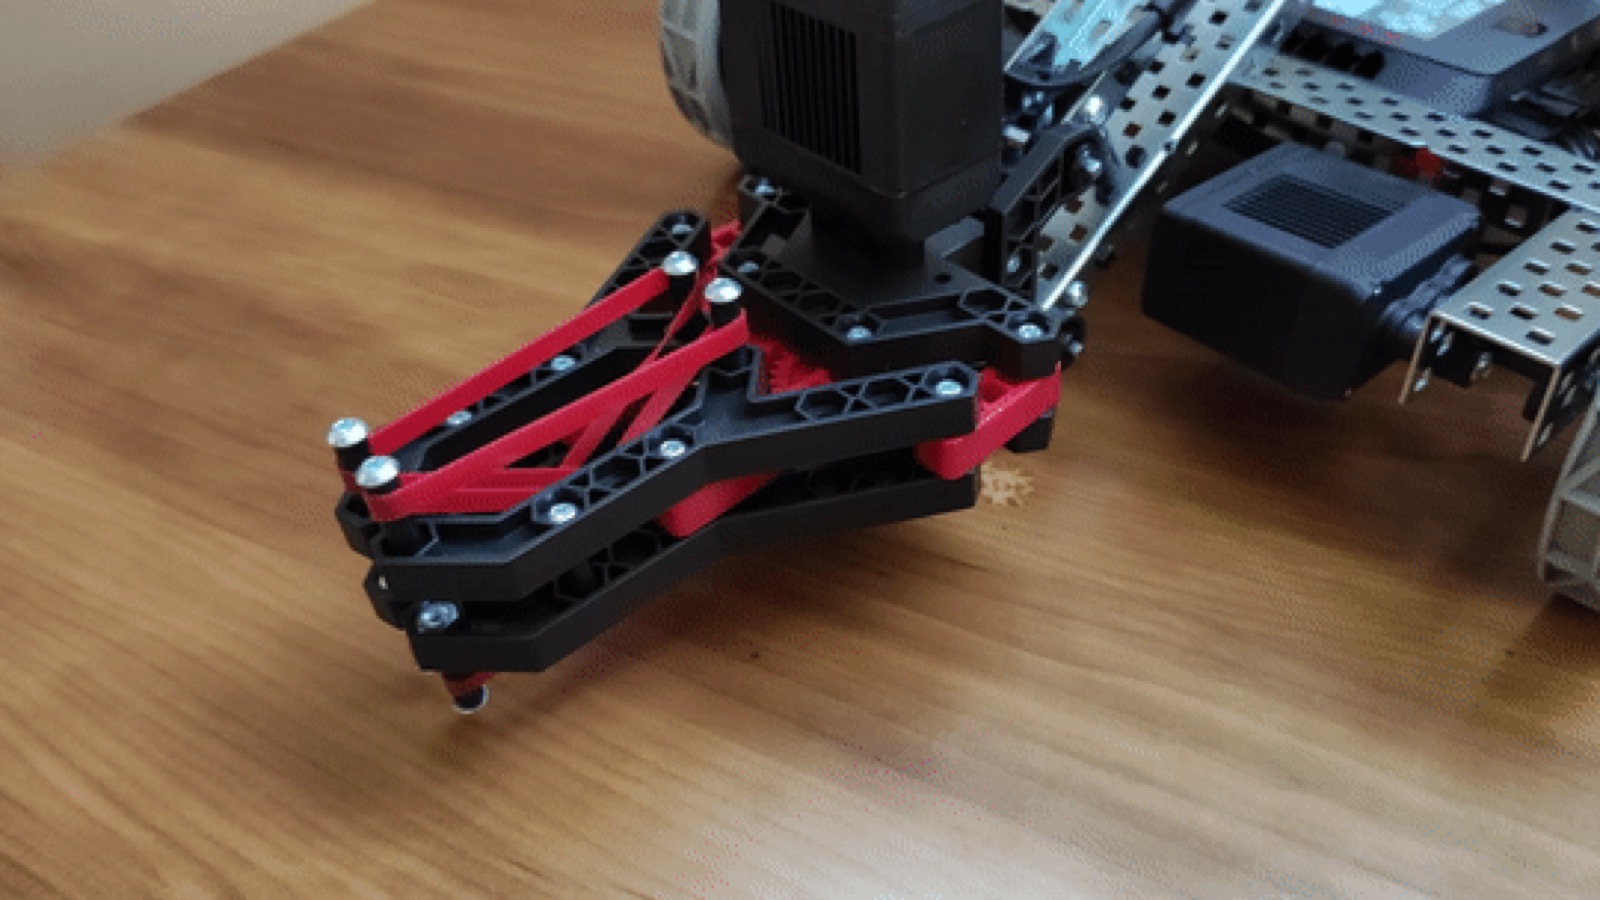
VEX Robot
What
A fully autonomous VEX robotics system engineered to identify
targets and execute precision object delivery.
How
Designed a dual function mechanical system with a high torque
claw for cup manipulation and a motorized ball escalator for
vertical transport. Integrated colour and proximity sensors to
map the track and automate positioning.
Results
Removed the need for human input entirely, reaching full
autonomy in identifying, tracking, and filling targets.
04
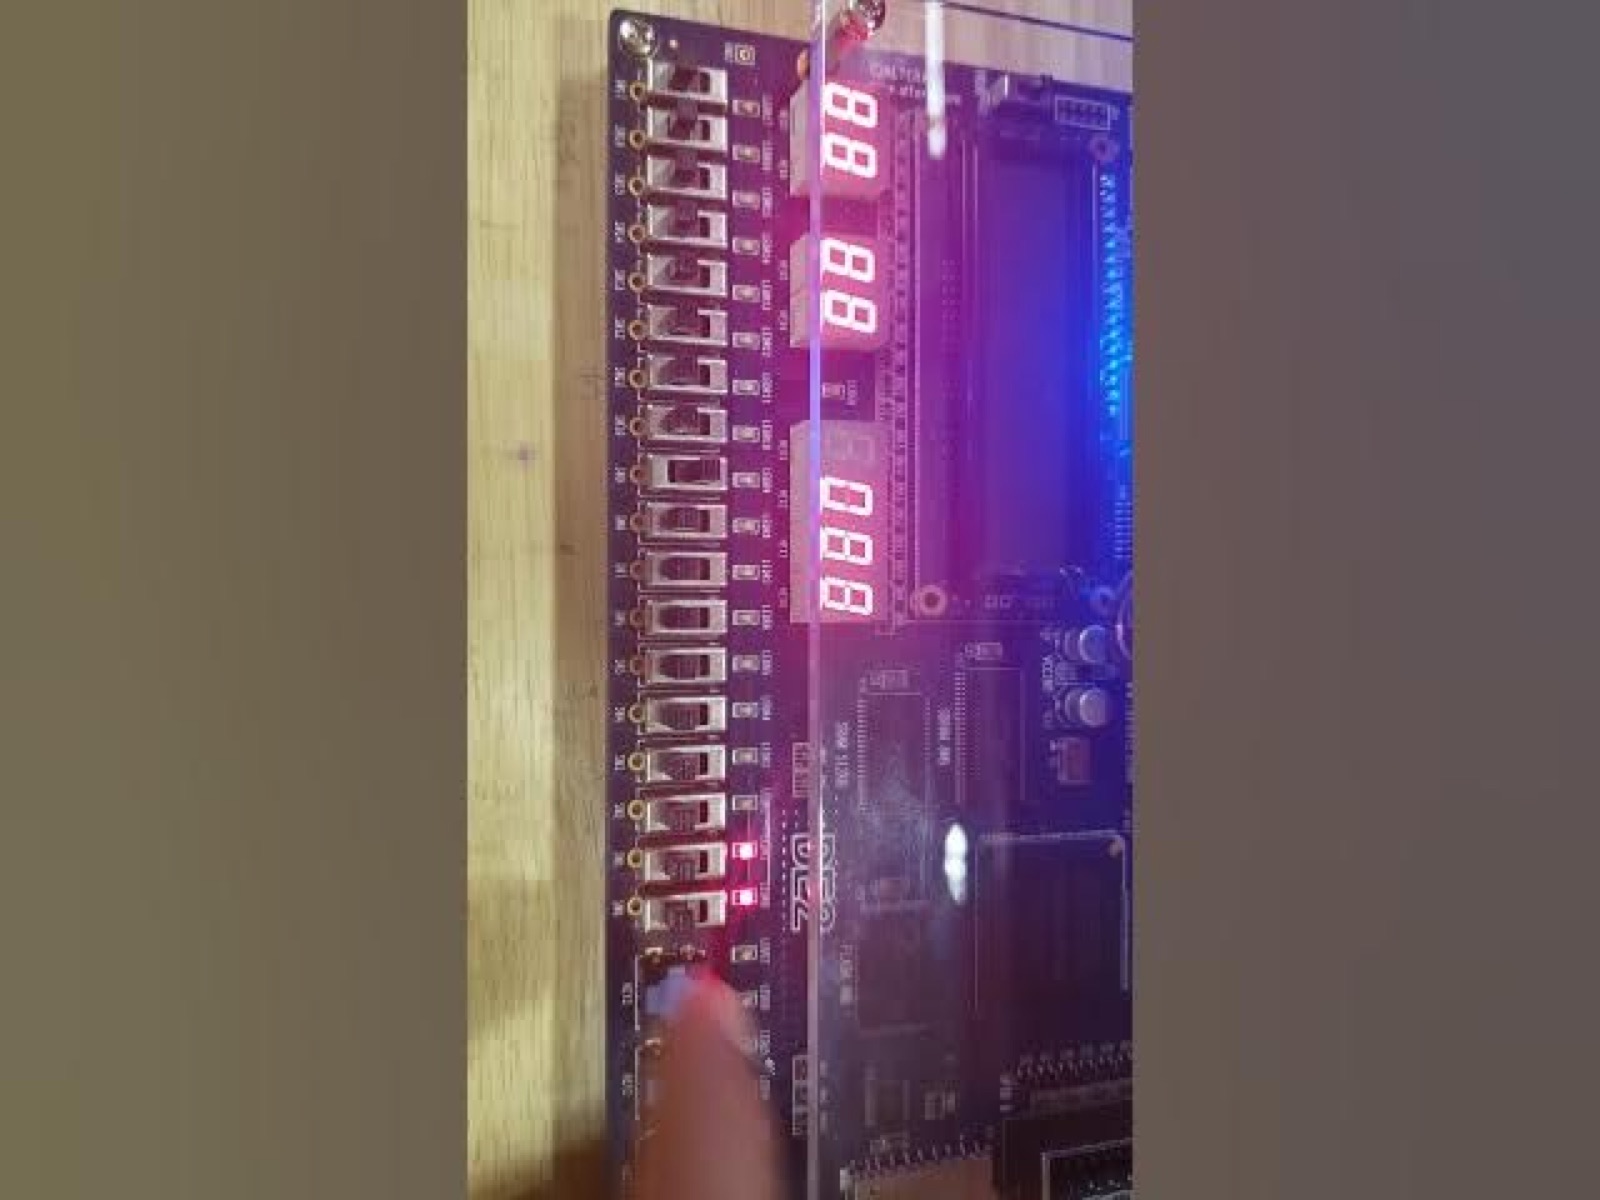
8-Bit Processor
What
A functional 8-bit general purpose processor core with an
arithmetic logic unit and a custom control unit, implemented
on an FPGA board.
How
Developed modular VHDL components, the ALU, finite state
machine, and registers, in Quartus II to execute nine distinct
arithmetic and logical functions.
Results
A processing unit that translates 16-bit microcode into real
time operations, with results shown in hexadecimal on a dual
seven segment display.